I build systems
that see, reason,
and act.
I like building the whole thing—not just the model. That might mean wiring a sensor, training a vision system, or making the software reliable enough to use outside a lab.
Four fields. One practice.
Most of my work lives between these fields. A camera problem turns into a data problem; a model becomes an API; an API ends up controlling something that moves.
Robotics &
Embodied AI
Physical intelligence, robot learning, perception hardware, simulation.
UNIVERSAL ROBOTS / KO-BR / ROV / UAVVision &
Deep Learning
Multimodal models, gaze estimation, medical AI, experimental research.
IEEE / SURGICAL AI / AUCLLM Systems &
Software
Agentic architectures, production APIs, tools, orchestration and ML infrastructure.
GRAVITATE / TRUSTCLOUD / FASTAPIHardware &
Infrastructure
Electronics, embedded devices, networking, systems programming and DevOps.
C++ / VHDL / LINUX / NETWORKSWhere the work happens.
Here are the projects, research and teams that shaped the way I work. Pick a field to dig into the details.
Giving intelligence
a body.
Building machines that interact with the world: robot data, manipulation, real-time sensing, and everything that must work before a policy can learn.
 REAL MACHINES / REAL DATA / REAL CONSTRAINTS
Robot learning infrastructure at ko-br
UR10e manipulation, RGB-D sensing, lead-arm encoders, data quality, physical-intelligence model research and digital twins.
Universal Robots
I joined Universal Robots in Munich in 2026, adding an industrial robotics perspective to my hands-on R&D.
Field robotics / fixed-wing UAVs and ROVs
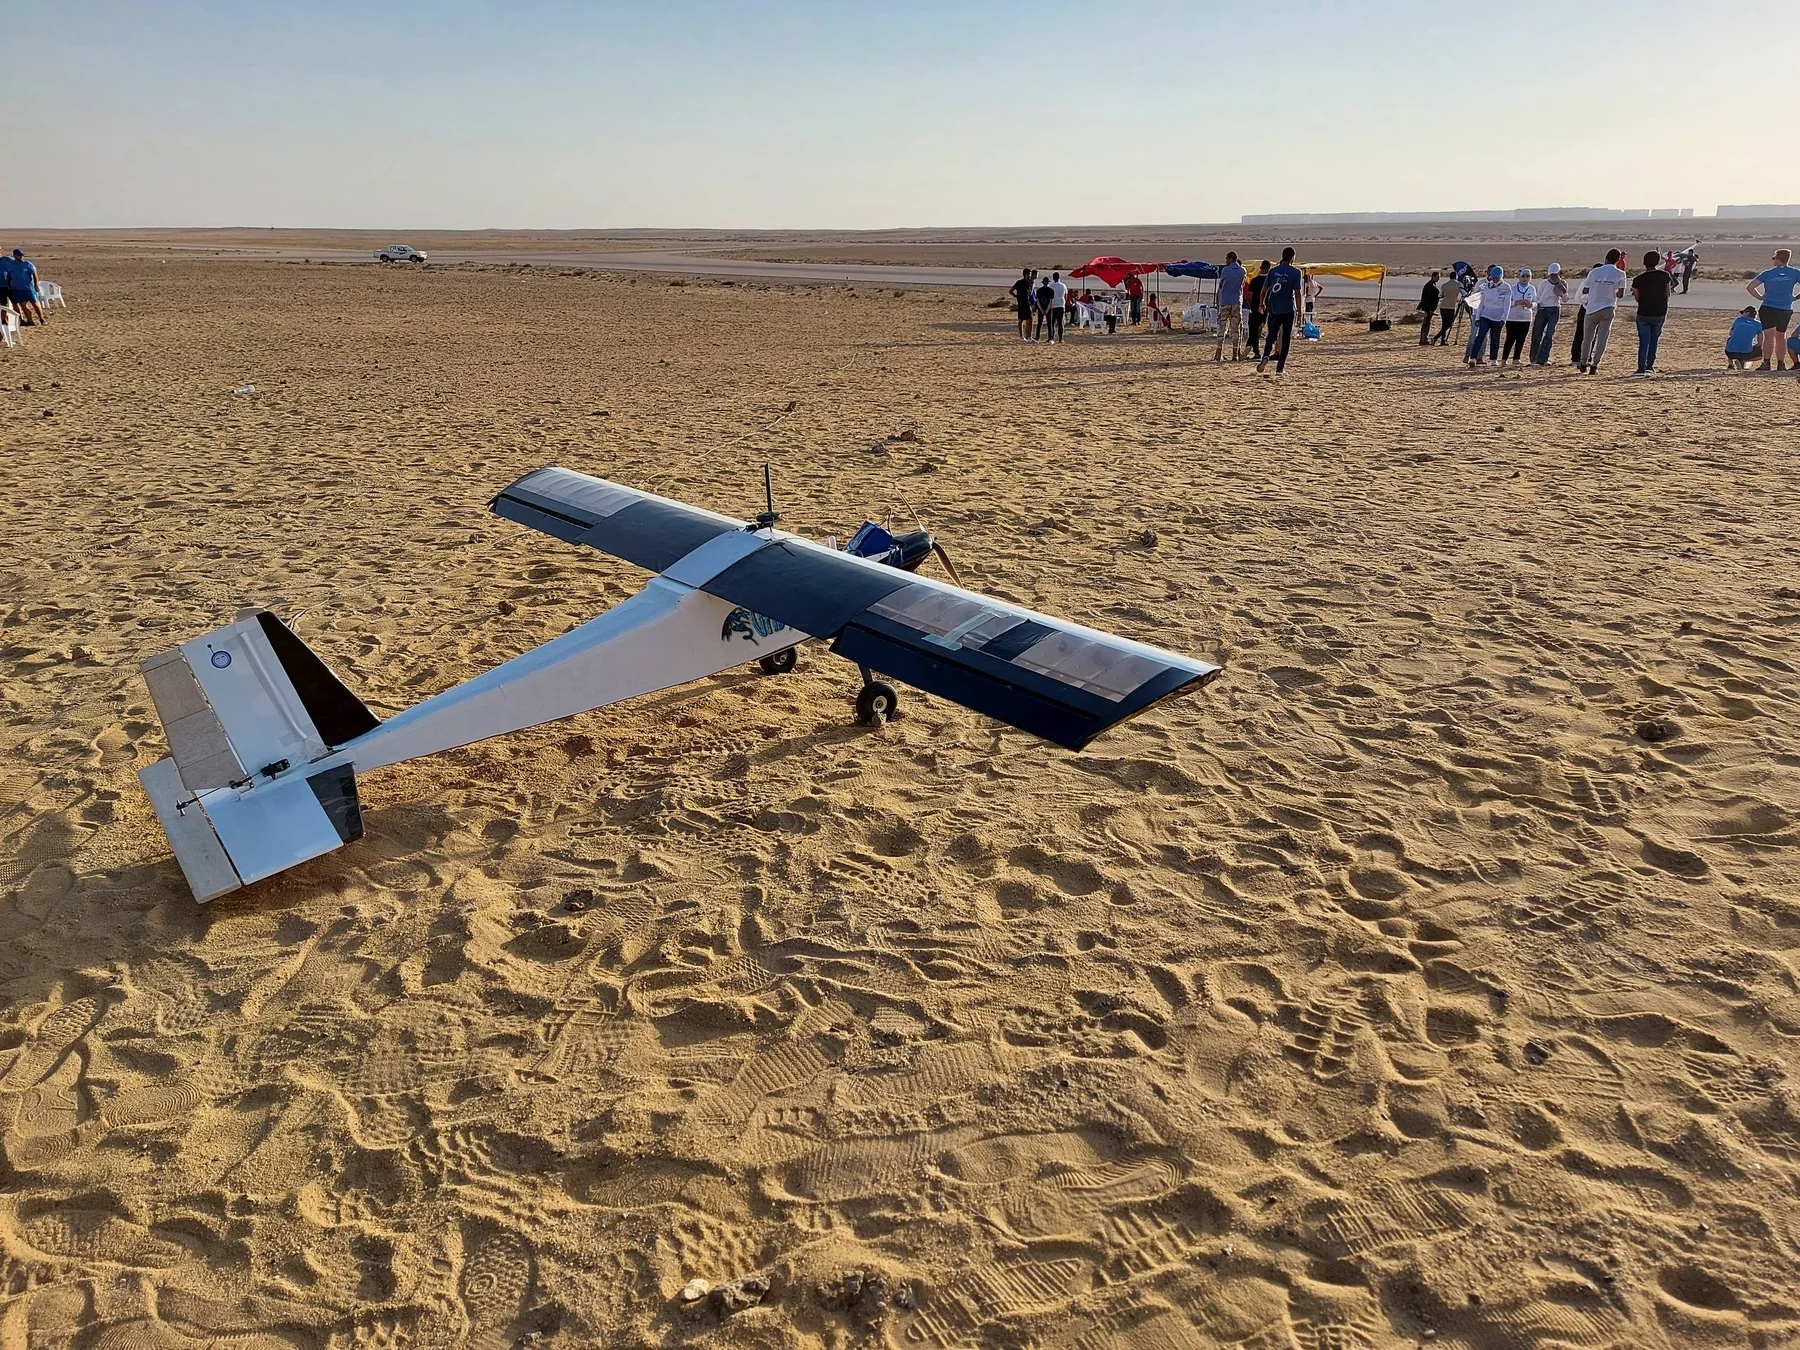
Flight and subsea software, real-time computer vision and field competitions with RobEn; author and maintainer of rovlib.
Teaching systems
to perceive.
Research-driven machine learning: turning pixels, landmarks and human movement into measurable information.

Measuring surgical skill with computer vision
Co-authored research with medical professionals affiliated with Harvard Medical School. I contributed to the vision system that quantifies motion during cardiothoracic suturing.
Read the research case study ↗Multimodal gaze estimation from a webcam
First-author IEEE research combining eye images and landmark metrics. Reported 8% mean screen-distance error.
AUC research / cognition and autonomous systems
Eye tracking and human learning, EyeMeta research instrumentation, and adversarial testing in CARLA.
From a model
to a system.
I enjoy the unglamorous work between a working demo and a system people can actually depend on: APIs, orchestration, testing and all the decisions in between.
Enterprise AI / Gravitate AI and TrustCloud
Translating cross-team feature requirements into prompt and architecture changes in large LangChain, LangGraph and FastAPI systems.
Local models, RAG and research prototypes
llama.cpp, ChromaDB, private assistants, agent tooling, model experimentation and security-focused LLM work.
Backend software and automation
Contract and freelance work in Django, Flask, FastAPI, deployment infrastructure and networked applications.
Comfortable below
the abstraction.
I came into AI through computer engineering. I still like opening the box, tracing the wiring and understanding what the software is really running on.
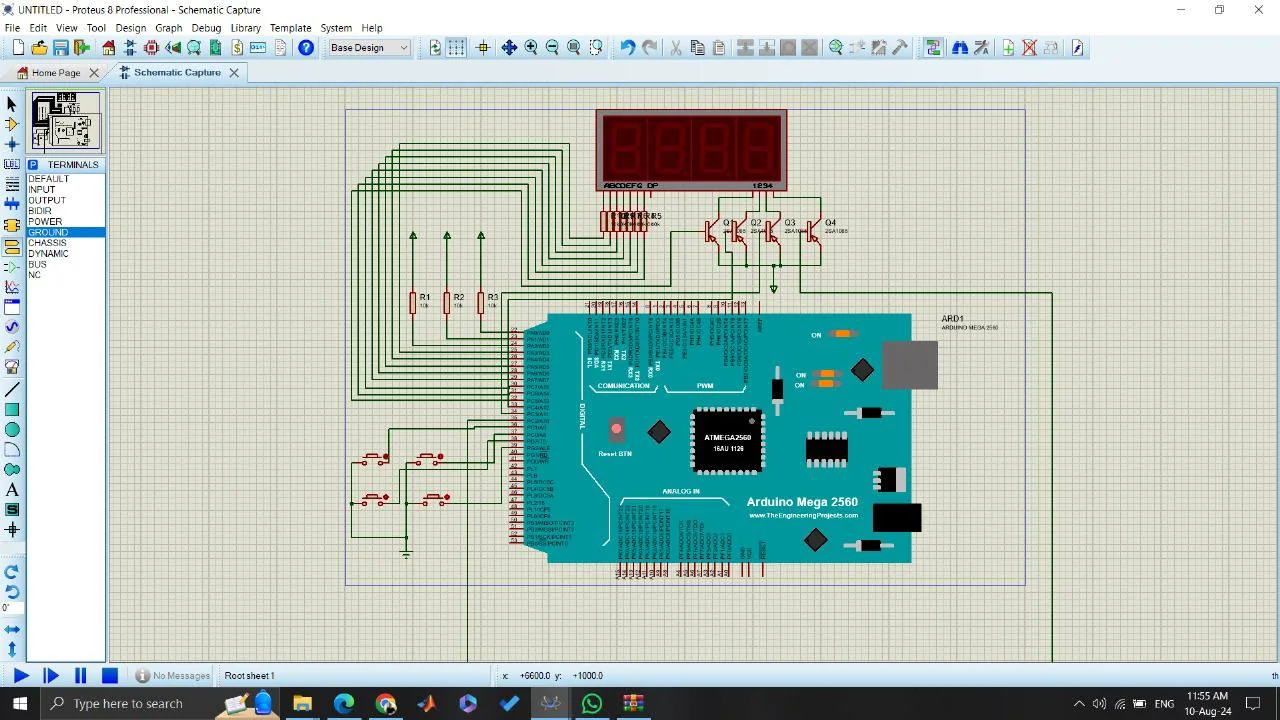
I still get my hands dirty.
I’ve designed processors in VHDL, written x86 assembly and C, built circuit boards, wired sensors, and assembled the computers and servers I use for local AI. The hands-on side has never really gone away.
Systems & network engineering
Linux, Docker, reverse proxies, private AI servers, Ethernet installations and device infrastructure.
Hardware integration & prototyping
Encoder wiring, soldering, reverse engineering, embedded projects and robotic peripherals.
Software engineering roots
Compression utilities in C, x86 assembly, industrial software, distributed Raspberry Pi systems, backend services and Django apps.
A few more things I’ve built.
Not every experiment needs a full case study. Here’s a quick way to find the smaller tools, side projects and research threads too.
Showing all 12 projects & threads
Research, in print.
I’ve been lucky to work with researchers in very different fields, from robotics to cognitive science and surgical training. These are the papers that came out of that work.
“Slow Is Smooth, Smooth Is Fast”: Artificial Intelligence-Driven Suturing Simulation for Cardiothoracic Surgical Training
Computer vision / Surgical education / Motion analysis
Gaze Tracking with Multi-Modal Neural Network in Desktop Environments Using Generic Web Camera
Multimodal deep learning / Human-computer interaction
Development of a Smart Multipurpose Underwater Vehicle for Subsea Operations
Underwater robotics / Control / Computer vision · Conference paper
Engineer by training.
Builder by habit.
I'm a computer engineer originally from Egypt, now based in Nürnberg. I've worked in research labs, startups, robotics teams and on software used by real businesses. I tend to learn a field by building something in it.
Away from work, I used to DJ professionally, and I still tend to have a Raspberry Pi or a computer build in progress. Some habits stick.
 AT UNIVERSAL ROBOTS / 2026
Build the system.
Teach the team.
At university, I spent almost four years leading RobEn's Software & AI team. We were around 40 engineers working across UAVs, ROVs, vision, security and DevOps. I wrote code alongside the team, taught new members, and built a Django tool so the next generation wouldn't have to redo the same administration.
We took our robots to MATE ROV and MCT UAV competitions, and our software teams joined coding and security challenges too. I still mentor members and give talks when I can.
TECHNICAL LEADERSHIP40
SOFTWARE & AI TEAM MEMBERSROV / UAV
FIELD ENGINEERING
Building something
interesting?
If you're working on something involving AI, robotics, or a slightly unreasonable engineering challenge, I'd love to hear about it.